


Morse Code is not dead. Here is my project to use 2 BBC micro:bits and a laptop to send Morse Code in both directions whilst also decoding Morse Code sent from both ends using button A or a proper key.
Step 1 upload the code using the Python Programmer On line.
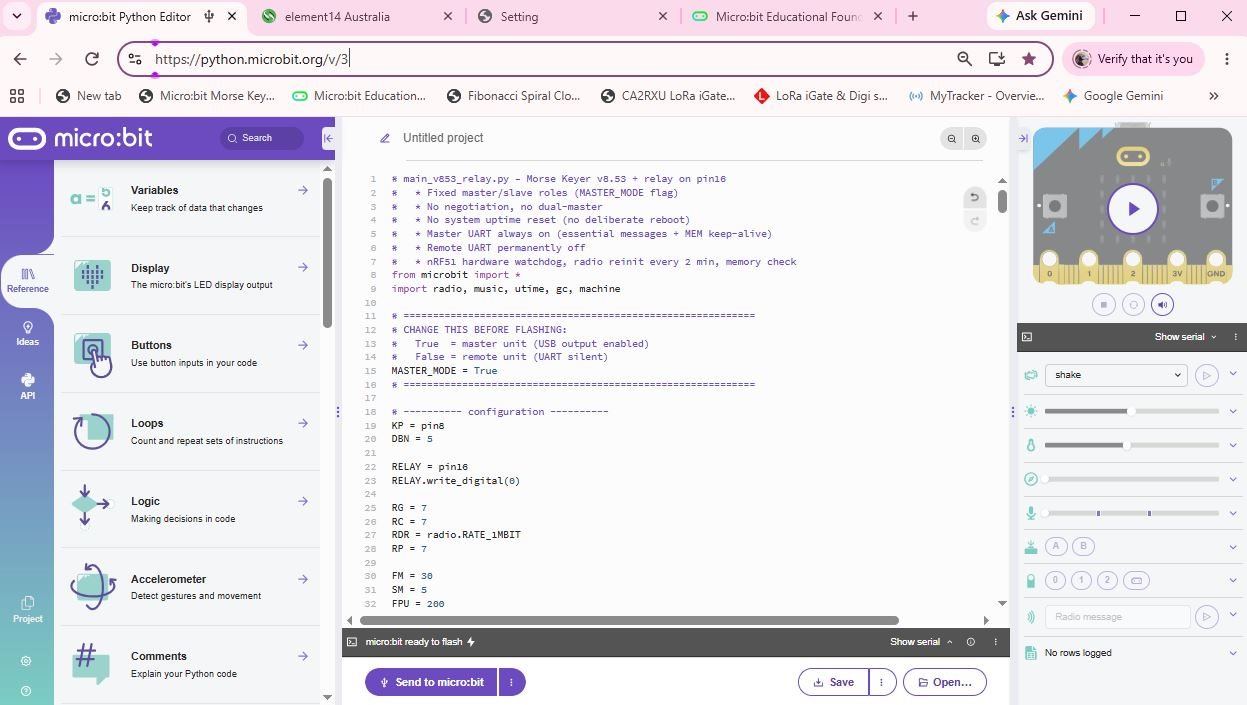
Remember to change 1 line of code to determine what end is connected to the laptop (Master). The USB port of the Remote or Slave end is not used, however it may be used for a variety of power connections of course.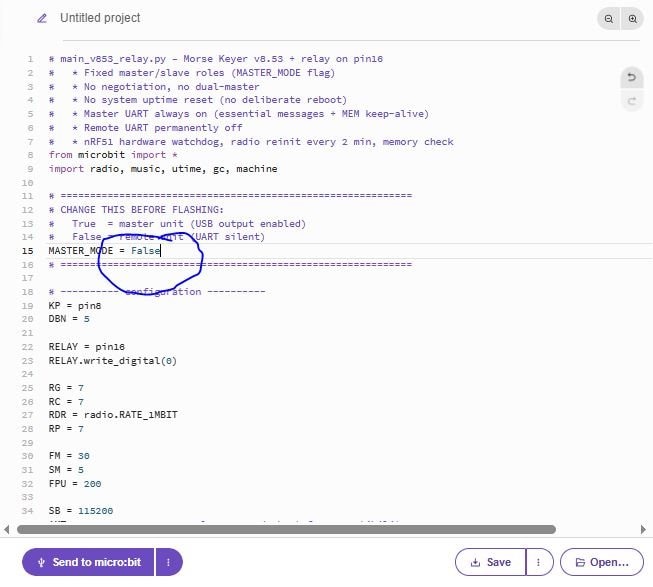
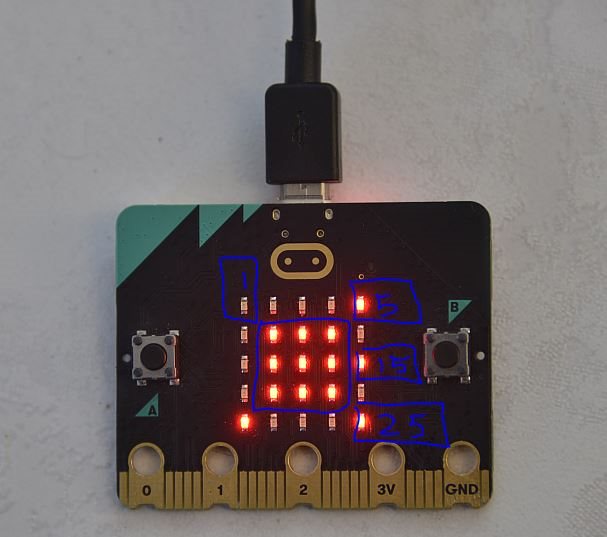
LED 1 is USB Tx LED 5 is USB Rx. LED 21 is WiFi Tx and Led 25 is WiFi Rx. LED 11 is Master end, LED 15 is Slave. The 9 LEDs in the middle are the Morse Code Display.
Here is a short example of the sender using button A, the message windows to send pre made messages and the 2 decoder windows in operation.
Here is the code for the micro:bit . V2.2 and above is required.
# main_v854_relay.py – Morse Keyer v8.54 + HL-52 relay (active-low)
#   * v8.54: relay polarity fixed for HL-52 active-low modules
#           - RELAY_ACTIVE_LOW = True  -> write 0 to energise relay
#           - RELAY_ACTIVE_LOW = False -> write 1 to energise relay
#           - P16 starts de-energised at boot
#   * Everything else identical to v8.53 (radio, TDMA, keying, USB, WDT)
from microbit import *
import radio, music, utime, gc, machine

# ============================================================
# ROLE:  True = master unit (USB output enabled)
#        False = remote unit (UART silent)
MASTER_MODE = True

# RELAY POLARITY:
#   HL-52 V1.0 relay board  -> True  (active-LOW: 0 = relay ON)
#   Active-HIGH relay board -> False (1 = relay ON)
RELAY_ACTIVE_LOW = True
# ============================================================

# ---------- configuration ----------
KP = pin8
DBN = 5

RELAY = pin16

def relay_set(on):
    """Drive the relay pin respecting the configured polarity."""
    if RELAY_ACTIVE_LOW:
        RELAY.write_digital(0 if on else 1)
    else:
        RELAY.write_digital(1 if on else 0)

# Relay de-energised at boot (prevents the "always-on" symptom)
relay_set(False)

RG = 7
RC = 7
RDR = radio.RATE_1MBIT
RP = 7

FM = 30
SM = 5
FPU = 200

SB = 115200
AMT = 10000
LMT = 30000
MFT = 3
WRT = 120000

LBM = 300
TXM = 300
RXM = 300
PIM = 2000

CLT = 3000
COB = 9
CLB = 4

WPM = 20
FF = 1.0
DM = 1200 // WPM
DAM = 3 * DM
EGM = DM
CGM = int(3 * DM * FF)
WGM = int(7 * DM * FF)

EBI = 10
MEB = 1
MSC = 256

MASTER_LOCAL_TONE = 800
SLAVE_LOCAL_TONE  = 600
REMOTE_TONE       = 1000

MT = {
    'A': '.-', 'B': '-...', 'C': '-.-.', 'D': '-..', 'E': '.',
    'F': '..-.', 'G': '--.', 'H': '....', 'I': '..', 'J': '.---',
    'K': '-.-', 'L': '.-..', 'M': '--', 'N': '-.', 'O': '---',
    'P': '.--.', 'Q': '--.-', 'R': '.-.', 'S': '...', 'T': '-',
    'U': '..-', 'V': '...-', 'W': '.--', 'X': '-..-', 'Y': '-.--',
    'Z': '--..',
    '0': '-----', '1': '.----', '2': '..---', '3': '...--',
    '4': '....-', '5': '.....', '6': '-....', '7': '--...',
    '8': '---..', '9': '----.',
    ' ': ' ',
    '.': '.-.-.-', ',': '--..--', '?': '..--..', '/': '-..-.',
    '=': '-...-', '+': '.-.-.', '-': '-....-', '@': '.--.-.',
    '!': '-.-.--', '&': '.-...', '(': '-.--.', ')': '-.--.-',
    ':': '---...', ';': '-.-.-.', "'": '.----.', '"': '.-..-.',
    '_': '..--.-', '$': '...-..-'
}

KP.set_pull(KP.PULL_UP)

# ---------- global state ----------
R = 'M' if MASTER_MODE else 'S'
MFS = 0
SFB = 0
STT = 0

PK = 0
SK = 0
EL = 0
LEL = -1
RK = 0
LR = -1

KR = 0
KST = 0

SD = False
ST = []
SI = 0
SNC = 0
SST = 0

LES = 0
BT = 0
LRR = 0
LPS = 0

LUR = 0
LUT = 0
LRX = 0
LTX = 0
LMA = 0

LHS = 0
RHI = 1000
HLD = FM * 10
HTX = False
HRX = False
HLO = 0

LUB = 0
UBO = False
UBT = 0

TXO = 0
RXO = 0

MCO = False
RCO = False

MC = False
MCS = 0
MCB = 500
MCR = 1000

_pending_words = []
_word_done_flag = False
_waiting_for_gap = False
_next_word_time = 0
_pending_word_next = ""

_seed = 0

# ---------- v8.53 crash protection ----------
UART_ENABLED = MASTER_MODE

RADIO_FORCE_REINIT_MS = 120000
RADIO_SILENCE_LIMIT   = 300000
RADIO_DEAD_LIMIT      = 60000
MEM_CHECK_MS          = 30000
MEM_THRESHOLD         = 4096

last_radio_reinit = 0
last_audio_freq = 0

# ---------- nRF51 hardware watchdog ----------
WDT_START = 0x40010000
WDT_STOP  = 0x40010004
WDT_CRV   = 0x40010504
WDT_RREN  = 0x40010508
WDT_RR0   = 0x40010600

def setup_wdt(timeout_sec=8):
    try:
        machine.mem32[WDT_STOP] = 1
        utime.sleep_ms(1)
        machine.mem32[WDT_CRV] = 32768 * timeout_sec
        machine.mem32[WDT_RREN] = 0x01
        machine.mem32[WDT_START] = 1
        return True
    except:
        return False

WDT_READY = setup_wdt(8)

def feed_wdt():
    if WDT_READY:
        machine.mem32[WDT_RR0] = 0x6E524635

def safe_radio_send(msg):
    try:
        radio.send(msg)
        return True
    except:
        rri()
        return False

def rri():
    global R, MFS, SFB, STT, MC, LAST_RADIO_ACT, last_radio_reinit
    radio.off()
    utime.sleep_ms(50)
    radio.on()
    utime.sleep_ms(50)
    radio.config(group=RG, channel=RC, power=RP, data_rate=RDR)
    MFS = 0; SFB = 0; STT = 0; MC = False
    LAST_RADIO_ACT = running_time()
    last_radio_reinit = running_time()
    if UART_ENABLED:
        dbg("Reinit")

# ---------- helpers ----------
def pr(m):
    global _seed
    _seed = (_seed * 1103515245 + 12345) & 0x7fffffff
    return _seed % m

def ul():
    global HTX, HRX, HLO, UBO, UBT, MCO, RCO, TXO, RXO
    n = running_time()
    display.set_pixel(0,0,9 if (n-LUR<LBM) else 0)
    display.set_pixel(4,0,9 if ((n-LUT<LBM) or UBO) else 0)
    if R=='M':
        b=COB if MCO else CLB
        display.set_pixel(0,2,b)
        display.set_pixel(4,2,0)
    elif R=='S':
        b=COB if RCO else CLB
        display.set_pixel(4,2,b)
        display.set_pixel(0,2,0)
    else:
        display.set_pixel(0,2,0)
        display.set_pixel(4,2,0)
    rx_on = (n<RXO) or HRX
    display.set_pixel(0,4,9 if rx_on else 0)
    tx_on = (n<TXO) or HTX
    display.set_pixel(4,4,9 if tx_on else 0)
    if HTX and n>=HLO: HTX=False
    if HRX and n>=HLO: HRX=False
    if UBO and n>=UBT: UBO=False
    active = EL or RK
    for y in range(1,4):
        for x in range(1,4):
            display.set_pixel(x,y,9 if active else 0)
    # ---- v8.54: polarity-aware relay drive ----
    relay_set(bool(active))

def uw(d):
    global LUT
    if UART_ENABLED:
        uart.write(d)
        LUT = running_time()

def dbg(m):
    # Debug messages are NOT sent in v8.5x to keep USB traffic light.
    pass

def ss(w,f=1.0):
    global DM,DAM,EGM,CGM,WGM,WPM,FF
    WPM=w
    FF=f
    DM=1200//WPM
    DAM=3*DM
    EGM=DM
    CGM=int(3*DM*f)
    WGM=int(7*DM*f)

def me(t):
    return [MT.get(c,'') for c in t.upper()]

def btl_single_word(w):
    tm = []
    mw = me(w)
    for ci, c in enumerate(mw):
        for i, s in enumerate(c):
            tm.append((DM if s == '.' else DAM, 1))
            if i < len(c) - 1:
                tm.append((EGM, 0))
        if ci < len(mw) - 1:
            tm.append((CGM, 0))
    if tm and tm[-1][1] == 0:
        tm.pop()
    return tm

def ssnd_word(w):
    global SD,ST,SI,SNC,SK,SST
    tm = btl_single_word(w)
    if not tm:
        return False
    ST = tm
    SI = 0
    SK = tm[0][1]
    SNC = running_time() + tm[0][0]
    SST = running_time()
    SD = True
    return True

def abt():
    global SD,SK,ST,SI,SNC,_pending_words,_word_done_flag
    global _waiting_for_gap, _pending_word_next
    SD=False
    SK=0
    ST=[]
    SI=0
    SNC=0
    _pending_words = []
    _word_done_flag = False
    _waiting_for_gap = False
    _pending_word_next = ""

def usd():
    global SD,SI,SNC,SK,_word_done_flag
    if not SD: return
    n=running_time()
    if n-SST>120000: abt(); return
    if n>=SNC:
        SI+=1
        if SI>=len(ST):
            SD=False
            SK=0
            _word_done_flag = True
            return
        SK=ST[SI][1]
        SNC+=ST[SI][0]
        if SNC<n: SNC=n+ST[SI][0]

def send_ev(et, st, ts):
    if UART_ENABLED:
        uart.write("E," + et + str(st) + "," + str(ts) + "\n")
        LUT = running_time()

def upk():
    global PK,KR,KST
    raw=1 if (KP.read_digital()==0 or button_a.is_pressed()) else 0
    n=running_time()
    if raw!=KR: KR=raw; KST=n
    if n-KST>=DBN and PK!=raw: PK=raw

cbuf=""

def pcmd(c):
    global LUR,_pending_words,_word_done_flag,_waiting_for_gap,_pending_word_next
    c=c.strip()
    if not c: return
    LUR=running_time()
    if c=='X': abt(); return
    if c=='RST': dbg("USB RST"); reset()
    if 'T' in c:
        p=c.split('T',1)
        sp=p[0]
        txt=p[1] if len(p)>1 else ""
        if 'F' in sp:
            fi=sp.find('F')
            fp=sp[fi+1:].split(',')
            try:
                w=int(fp[0])
                f=float(fp[1]) if len(fp)>1 else 1.0
                ss(w,f)
            except: pass
        if txt:
            words = [w for w in txt.split() if w]
            if words:
                abt()
                _pending_words = words[1:]
                _word_done_flag = False
                _waiting_for_gap = False
                _pending_word_next = ""
                ssnd_word(words[0])
    elif 'F' in c:
        fi=c.find('F')
        fp=c[fi+1:].split(',')
        try:
            w=int(fp[0])
            f=float(fp[1]) if len(fp)>1 else 1.0
            ss(w,f)
        except: pass

# ---------- main ----------
def main():
    global R,MFS,SFB,STT,EL,LEL,RK,LR,LES,SK,SD,cbuf,BT,LRR,LPS
    global LUR,LUT,LRX,LTX,LMA,LHS,HTX,HRX,HLO,LUB,UBO,UBT,MCO,RCO,TXO,RXO
    global MC,MCS,_pending_words,_word_done_flag,_waiting_for_gap,_next_word_time,_pending_word_next
    global LAST_RADIO_ACT, REINIT_PENDING, REINIT_TIME, UART_ENABLED
    global last_radio_reinit, last_audio_freq
    uart.init(baudrate=SB)
    utime.sleep_ms(100)
    radio.on()
    utime.sleep_ms(100)
    radio.config(group=RG, channel=RC, power=RP, data_rate=RDR)
    display.scroll("v8.54", delay=80)
    sleep(3000)
    display.clear()
    global _seed
    _seed=running_time()&0x7fffffff
    BT=running_time()
    LRR=BT; LPS=BT; LES=BT
    LEL=0; LR=0; LMA=BT
    LUR=0; LUT=0; LRX=0; LTX=0
    LHS=0; LUB=0; TXO=0; RXO=0
    MC=False
    _pending_words = []
    _word_done_flag = False
    _waiting_for_gap = False
    _next_word_time = 0
    _pending_word_next = ""
    last_blink = BT
    LAST_RADIO_ACT = BT
    REINIT_PENDING = False
    REINIT_TIME = 0
    last_radio_reinit = BT
    last_audio_freq = 0
    next_mem_report = BT + MEM_CHECK_MS
    if R == 'M':
        MFS = BT
    else:
        SFB = 0
    # Ensure relay is off at start of main loop
    relay_set(False)

    while True:
        n=running_time()

        feed_wdt()

        if n - last_radio_reinit > RADIO_FORCE_REINIT_MS:
            rri()

        if n >= next_mem_report:
            free = gc.mem_free()
            if UART_ENABLED:
                uw("MEM:"+str(free)+"\n")
            if free < MEM_THRESHOLD:
                gc.collect()
                if gc.mem_free() < MEM_THRESHOLD:
                    machine.reset()
            next_mem_report = n + MEM_CHECK_MS

        if n - LAST_RADIO_ACT > RADIO_SILENCE_LIMIT:
            if not REINIT_PENDING:
                rri()
            else:
                if n - REINIT_TIME > RADIO_DEAD_LIMIT:
                    machine.reset()

        if uart.any():
            ch=uart.read(1)
            if ch:
                c=ch.decode()
                if c=='\n': pcmd(cbuf); cbuf=""
                else: cbuf+=c
            LUR=n

        upk()
        EL=PK or SK

        pkt=radio.receive()
        if pkt:
            LRX=n; LRR=n; RXO=n+RXM
            is_M = (pkt[0]=='M' and len(pkt)==2 and pkt[1].isdigit())
            is_S = (pkt[0]=='S' and len(pkt)==2 and pkt[1].isdigit())
            if is_M:
                LAST_RADIO_ACT = n
                st = int(pkt[1])
                if R == 'S':
                    SFB = n
                    STT = SFB + SM
                if st != RK:
                    RK = st
                    send_ev('R', RK, n)
                    LMA = n
            elif is_S:
                LAST_RADIO_ACT = n
                try:
                    st = int(pkt[1])
                    if st != RK:
                        RK = st
                        send_ev('R', RK, n)
                        LMA = n
                except:
                    pass
            else:
                for _ in range(10):
                    if radio.receive() is None:
                        break

        if R == 'S' and (n - LRR > WRT):
            rri()
            LRR = running_time()

        if R=='M': MCO=(n-LRR)<CLT
        elif R=='S': RCO=(n-LRR)<CLT
        else: RCO=False

        if R == 'M' and n - MFS >= FM:
            MFS = n
            msg = 'M' + str(EL)
            if safe_radio_send(msg):
                LAST_RADIO_ACT = n
            LTX=n; TXO=n+TXM; utime.sleep_us(FPU)
        if R == 'S' and SFB != 0 and n >= STT:
            msg = 'S' + str(EL)
            if safe_radio_send(msg):
                LAST_RADIO_ACT = n
            LTX=n; TXO=n+TXM
            STT += FM
            utime.sleep_us(FPU)

        if EL or RK:
            new_freq = MASTER_LOCAL_TONE if (R=='M' and EL) else (SLAVE_LOCAL_TONE if (R=='S' and EL) else REMOTE_TONE)
            if new_freq != last_audio_freq:
                music.pitch(int(new_freq), -1)
                last_audio_freq = new_freq
        else:
            if last_audio_freq != 0:
                music.stop()
                last_audio_freq = 0

        if n-LUB>=RHI:
            LUB=n; UBO=True; UBT=n+HLD

        if EL!=LEL:
            LEL=EL
            send_ev('L', EL, n)
            LMA=n

        if SD: usd()

        if _word_done_flag:
            _word_done_flag = False
            if _pending_words:
                _next_word_time = n + WGM
                _pending_word_next = _pending_words.pop(0)
                _waiting_for_gap = True
            else:
                uw("DONE\n")

        if _waiting_for_gap and n >= _next_word_time:
            _waiting_for_gap = False
            ssnd_word(_pending_word_next)

        if n - last_blink >= 10000:
            last_blink = n
            display.set_pixel(2,2,9) if display.get_pixel(2,2)==0 else display.set_pixel(2,2,0)

        ul()
        utime.sleep_ms(5)
        gc.collect()

try:
    main()
except Exception as e:
    if UART_ENABLED:
        uart.write("CRASH:"+str(e)+"\n")
    display.scroll("ERR")
    sleep(500)
    reset()
I had to change.py to .txt. Here is the code for your Windows laptop so it will do the stats and also decode in real time.
Again .py changed to .txt. Just cut and paste into your editor. I use Idle available for free at Python.org.
I also made provision for a relay output and an external key input using the micro:bit driver expansion board Version 2.0 however the relays I used were too slow to keep up and so I suggest using a solid state version matched to your Ham Radio transceiver. It is handy for a Key on P8 and relay on P16 though. My relay board was a fake with no opto isolation :( It was horrible.
Using this from a .cmd prompt "pyinstaller --onefile --windowed --name "MorseDashboard841" --icon=morse.ico --add-data "morse.ico:." FasterMorse_841.py" I can turn the above files into an executable file, so you can give it to a friend that does not even need to have Python installed.
�6@@ �
�� � ��PNG
IHDR ���IDATx��VkLW���}���"�+�lLQP
�1�_�.�VVkLZ��iMmj�U��jŦ
���m�����G�j�VlSkD)��������6�CM��~�f����;�
d��� .�\4�����hU���~�R�Psss]]�����m�۷n��
X�a```FN�k��� !RX�w����0
PJ1�]�.�Օ��B!��&[�m������U�
�N����<n7�@
�=
��fC�,��*FQ��B(�c�
�����'��ޡ!��X
�;33s$�E!����v��=�c��zxt9b
B����t��^�W�|þ��<�f!z���F����AI�BG����-�X��hNvY��ή.��,���֎��:��(®�̟9�����
�w)���J�°oْ%٦E��,{�
�c;v�f���/�?�%\k�}\9>9�����{}]eq�iq�5;�r�� U�O�͝��bKKKMM���b3���C�i�?�E�'���A�������%�[]���J}�{����$����夛����l�R�|A�ۦ4�į��q�����kMM�vm[��I
#��D�
^�zE)c��f��C��.�����ƾW�
���%{jV=p
�U�ѷo������Y fs��/!����`1`�y^#�����+��������p|sz��r��q &��
�]����O
o4�y�P�5v�\�x
��Y"0h�
C�
ch^1���nߥ&i�c�H��Dְ������-�{����;oT$�T
ۼe����)�U8%�����W��A���ge�_Zb˖/Ux ��r����,SJ���h�+
�K�U����>�ZX[� G&n*�k��ҏ��_̚���1�|̠����zv���
��y���s�~����˹S4�{���� �����I��OO����
�$IzZ�s
�A�ޡ�5;%��5��h�5~��4$+��E����(�aI
����0��r'ϴ��謨� �`��hS�qd\�w8O5
������3g�?�c��3�8�M�!H�����9�����p�;�^3M������ykU��<�(��[��-Ι��癮�M�uZ���yZF�
�j��b�M]�����4ߘ��uH��
j�hrsf0�h����h�
i8l�X������2���`H�ኃ!���
"0N�A?n��
P��0�z ��b
;�D�ڸ���ݓ���
x�LFIL��`�LPXS��n@CSJ"�(�2
��BYe���+��q
E��y�qf1���x6@�8�w9oݼ�M�$�#d0�`~Fj?DI�`0p���
cJӁhBe�ɲLy�Ѣ��"�J����y^�B
�N�S���,��Q
!�$Q�z�=N�a�A �l��Q�0�Q�uO����W�/�
w]}Z
IEND�B`��PNG
IHDR@@%
�
{IDATx��Z
pT���c_�d���H H
�!�� V�o[lu����J�V�����H�#Ԋm���iG�Ti�T�0D$&$a��n���8�tν�% �a���~�IrϽ�����u�s��20�q`��0�A!��9 �E1���@��D�9�b�rjmmmjj�4
!�Od�x��9s��l6�yB���1����n��6�l3f̨��B��
p�0n���͛7���O�4ɴu@)Z\״h$���
�G }�Z0�!555���
�g�ŋ22\\p�.B�iJoO/q��mS�
Sˉ��͏?�!4e��
�+��!�L �TM��;᫃wV�L-�K�8c�pi�e������V"Cs3�� ��CX7!��L#�(��ǧN�����B�~?��a�GHg�1
a
�F��s�ME���
C�`\QF�2��2�!
@EE�i�
ާ%�!�c�ҙ3g
!"�0&$I!�4�|c(�s�9��B�>BIW�u]f�oa�;k�,�1BI�!��T��������Q�L���n�3��R9=
F��͑��#���S6h�8.esd���ҏ�D~
��i�X�ř�J��=
=Nyt
Qs|�]]]_۰e�;�_
�G�N{��¥��?����hĔ��
�B���V��T�i?V�5����r���LlC(:��b
!(�ӊ���y7���� Z����[�\�͛���U��
���'�x��
H2g�e�}�E����U ����پ�$�l��i�ZZZ.�d1�V�9�XQ�p�b�t
�l;thӦM7�tSbecB�m۶��M
���������M�_�z�q���ݼO7�%��ŧ�Ů��ק>�i6j����gNa�qΛ���̙;�r����+�O�}('�V����pB̝;���I�������@ p��,�M��@���Æ����={�PJm6��-o_}͵�̴���[�m+ўz�p��˴�+# rvU���kh��������X,f���/���/���25f�:f�|Pw$���}���L7��\��۷/Y��n����I#nx�� UQ�~EE���9!���.|oq��d����A'`Z���5��Ǣ�l�8�����`�s�^������k�M�e�3V�]5��
T�x�ޕ�>����|>����D��߯N�}�p�n���g�4��
(++7)�1`߾}����P'Au��ESe��o�ڵ�I �Xw|X�48
BD4
���ŗ�!������<����փ�_8��+��+�����T���3���C�����'�[ J_z��������e���,�h�W
6��
Z�/���p
GC
�w�v[(~����;�
Mc�%������z�4����F��H,<0���?��zj��]'J�-�*u%�Wx���H�O��b��/�/�C~��撽�Σxd$=���to۶�h�u�R��3�W>��o_z֢K�jT�1.��[0A�^���5��V��� �N�p`��#�=�^z��7\Rzv���o��Y_���yi������؊�
i��l�G�P�97*}��ЂY"��h�4�D,,b
�����[�?���
��8煅:�%�����t����������\N��
��&M�aKZ��z�O��s�M����G�2vXiXU ~t
lr�
N��/n{Վ��VQP��9 &�U^
�o����u�
�JH �m_���D�Dv����������-��zn����|����w�Ag��hD�겝Ԃ�K�b��IA BcBW(%��q!D8���
��� !6l�`L��F��vn�,>�r����.�h{[��@�;?��
X:k���"��M�͂�ܙ���jG� X����r�����3�w��ֿ����sc��k�]��}�"����v7����T�-*����H ,
�X{�$�s��1ݞ���߷�g�����~��sJ��?��� ��h���;n��6M��1��h�)
!]gپ�ܼ��`x��E�3�n�&*/?{��9�]����@��\�糞�h�KU_}]��c��� ����G��pl�BB-��_@-r=���p��64��Z�)Κ��|j@� S8��m�\��Á�,��!�W�1>Z*cPU�_?�|�g`e��LMѾf�d�800��t#��~���{ռ��Q]���
����N�u3�
�i�W^^^TT��4.//�z�L�b��)
#`�
K��3�
u0,cΐ�0&�p�Ǐ _Y9���U�fG�<���R���ck��0`y
8i5!�&��2�
7^b��������t�����C���j1z�2�q!TM��|�'O
-�#�a9
�����q�p���qRDUU펴���o*�Y ~��g��
����oh����M����c�Q-Z���|�g�}�ݥK�
ww�$�i�_Uճr]3�]gH�
�P
�iu���^F�|RgBg��1,��\p��]20D#
�N]<��AF n�Zȗ�Z][O{{{r�q�Lq���Ym�M������Y�C�
�LȠW>����c����&��vS�bTC��=�0 0�)
PB�� f�2���
}�-�N
��
h�A��W.�'��NA���L.Ş��uk���F�*����`�BZ��_NN4@�}#nw���"!@�_��G�bL��]�,Ȇ���o^
h��| bqZ�ꃄ�[����ԙ�OT� B�Ʋ<�e˖Y��DTLvG�����<v�ؑd��^
36
F�uAE�7NPª!���ty�J��m�a�ث�L���d�
C 1u�8haBp!&�v+��'L��H�괽�-�k�E�%ٖI�t�L��X�.˺{�d��
"@z��7��������v'٦+W�lll�����@$`�l>��Egr�<�@�͏θ�ڬ��^E?��>��륥�#�TV�x�� ^rɹ��@�.!����?_�g9O�p
N(�XHY���
�"�
�bp��7�pC}C,�N
<^�C7�T7�4���HJ�"�ƕ��{����f�1�w6�
I)p@f�N�
'�h]�TJ�����S����40�q`�� ��������� �
�ؒR�HXm�
�0!�O����]
cX��q&�s��N�QQ��n�����C�ݎ��I!
R냧S=]�9��dM7v�a��>�
|S��iC��tu.IEND�B`��PNG
IHDR��L\�� }IDATx��} �Uř�WUg�[7�,�
t7�4 ����]��hԌI\G�8�<����8�eԉ��Itd&���$�*1d�D
%(#���mYYh���w;��2�W�}��_�2��}���S���U}�-oU�Q8�>���
��
(0�
(0�
(0�
(0�
(0�
(0�
(0�
(0�Bw�+�RB�5!$���1��bR�
��-��n�ee�PT��AJI)�����+Wnذ���EJIȀ�$Ç?�S�ϟ?z���vP�E� �R���w�qGee%
>***���x<n��,߇�!���n�Z__o��8�mۖe1��'���q֬Y[�lQJq
�
B)ess��ɓ���&!l�J�B�,>��q
�8q�}�8��5 /�}�W,Y�Ķ� HMM���p(
П�'DȠ��])E�ҙ}��577����W>��E
!clժUg�qc�,���=g�)R9pI�QH$
�2E mjjjllTJQJ��+V�(����5!�R�I'�4yꉩT��� �r
�R�h5UUU�R��۷��'�(F�C�1&�X�f�Y6ݐ;q�d/���e��a�p%P|
�P5ֶm)%�^����!`
Ng"�O�o�Tiii8
VR
:�����c
(�\F�&tسgOQyAI�+�R�.�y��.pm?�V>i())9r�_2��}�+�
FEٔ��~d23*++�
������C{�X&�N'���!�h�HBȀPer��L&��d���O�^T��0�>�䓍A�Rvtt�3���p�H2�
����ZT��0�2����6ts�s.�8��$$�H��/���M��8��mmm2DzT��ad$��* �Θ1�8�U����kjj̷�x��!��Y?��RJ9�t�48A����X��O�n�T:�L&�i���3�F�&#�N���xƌ�mp��0z�Rv��C��p�.��d2�$&���JQy��(�k
nm
������x�̙E
����\�5�pGkI��D�[p��(�@
��D!\ם6m���!�q
��Ѩ�����6?����2
%
Pa�=����ɤ�euuuUU楡p�:H��R&�k`�t�A ?�B8��]���t2���4���;��Nf.X.�H�RjYe4�e��ݳy��M�6��ՔL�0ѵVd�
'j��8VZ�@]ˍ�����I�ֹa��]�1FƐj�y�e˖��ꫛ6o9��@&�RR��HYYi����sf������g�e�Rp<�ím-5�@�~b� $�V��.I�����ʬ���
8��}�� ��裏�X���I��"�QD@N�9k��|�
7��F��@
� ��
�j�����Um[]]���0��<�,/(�EM�S��m]�P�bֆ
Z������_[[�U�Azi�!�q�9�K��3�o���^x�@�v��+�7R���%�v�$8^f̘��~�OC�s�m
�M��g����3g�ܼy3!$
�\�7ۮ������ttt$;�rvhH�z�j��RS�Ly��]�
���nmܸ���S��F[�I��5���SN7n\�����g,X���n;x��lʸ� c�Qe��`�ݹ7ز3�ɠ�,f1�q���~�3w�q��<`|�~�m�)˲:::֯ohjڍc==Ԯh�(�vj'�~��t�Q2\H!�̚뺳f�ڼy3�4�N}���F��A2�侧��"�|SEB��ׇB!3jap�%�\bx,������o;�L���ok�s�ԃ�H�v] @h���{���/��^��^�Wkg�7�����W���sS�2i^��orm��_�*�;�6�� ��d2J��
{l�� Cɓ~�S_~��l����lѢEcƌr��EB��ѣ �q����HH�6m?~<�
�V?v�
�\WB�ql�q��y睗H$�����~�����c�f�����7'����6�WoLL�Z�|etz��ԟNL-��OR��W�f���.�m^]U)��Աq(|᪫�8zi���{���yհ�D�H�uB!rܐ
���Z�k�nI�1�dɒ콃�\����4�3
3Y�:�]/.\�?5�8�g�u�B���5��
|��?���j�Q�l�2t+C�@N�4l�s�Ի՟k3�䯜��LV��ެU
��Ij�t�ꄎ�S��Wj�O���9H�1����
U�3r̓^z�%m���-��qQ��Y؎ g���)2��/_�����3���K��^���~����Νk۶��a�\>�z<
x��M���(p���1��U[��J���������R3����z��'�i��l'���'�,����3ʸ�B~Kx�{�u��;�~��ЩSb�g�Q�$�ĎQ�p��_l����*e��R���ks�����B
F�E�����eYA�;���
�m8 U�J;�t�p.�>?��e[�����2� ����~��A�n�/�x�ҥ�1�yUU��P�d2�� 3+�ю
���
�e���� i�f��6%A@������z�&8�Qh
���+�5Dә���{�{��mll�={�Y^8����}�w�;���XU�̃5##홸
E���O�&�س���
���:U#�k?=�[ה��~��@=rS���ܺ]V�ʌ���[�T�
��Q�J��}�m4\֍.Y����� *�P.�/�dǞGCsj��ݷ������j����?0�L��66�9/++���KKJJr���@(�茷w`�T*`�V���i�R��ذaC�
H��h�p����F�O��)ˢȄI+��,�l$�*1q�0X��RKH���̉�8[�n����Y��e���x-,V-钛�iyn�
i�6��sI��x��n�
xj��W�>{�����������8�a���-^(�444�v�o���/f'A�T
s/R����
��N�HB,agT2I��Q
�[j�Np
;�ɀRF�HP���}�j��fu��(��{�0�) ���p"�0����Ȯ������~�wϮ0e1�\1!b��ܲ3U�PÆس+��b��Ph�رJ"������K����o�̄y��~k�
g��Ko������ea��{�/�����f����{;��߱i�V�)���U�'���T��Ь��
}�D�{I�E�O�Le֛ �}�?��ʳ!�
�J}p�y8��Π���7�������4iR���B�X,f\m�ؾ}��}�ݼV]��< =9@d3��----fM
7n\�yg��鷺S[;�[��>&F++�\
��z*)�@v�io�f�
i;��)S4%�?cl� f2i"mױ�|���ꤟ"�������
{Bn�2Rʳ��_{�E3fV1fo�h�sO�X���� ��'W��v�_�vڇ�%��X�֮8� �:u���>n��]�v��PE��8>
�$ H��ٱ��Ki�����-ʥR�رcG�� `<�+[۹kW{[{��5|x9eLI�
��@`@Cե��x
@��w���� ��O
���Vu__�[Ŕ��A(���ܬea�C>{�H�f��r�Z3��G�0 �s��|E�וZ��kJ��_���~{_Ii��Q�CW֩ߝ���|�����<�e��K;��Ӄ�IJ
�L_���-]292P �h�q�ԩ����?3:X�pa�M�P
�v(�!
�upj�}�՛'z/MPo�]{� 8�]�ĭJ��<�r��E�Y���~�?��?(�q��{��sau����w�l��9k�=
��a&��$���]�#Cn
�|�����H���.���|��ӧ���� $�R�z��k��v���hY�;�ƑL"-u@(��%)�rϞ�#����W�e�S3*IZ�p�U;�Z=~����<S:
��ٱ�{Z� �z�X���Ғ�.����YV�s��?��;�L�E��O�}�G�
!v� QB���y
���
$¤���"Zes+�
�۾}�]w���01<PC}����O�4qҶm ���e���., ���>o�U��@xVY�K�1C��#�
�-�®�lo[±Þ �s�첑�LGk(6ꕥ������Խ
o���/�f��+�f*�
M�y��
D$3"�Q{F�`��WΉ�)�b* k��h��S���K� �
�
����� ��r�~���W�b� p�� m��Q���ńpj53��E��Ƹ�&�h"��ĥrCLyR[�z���B�$�QJ`�{�߳����>�寜7,���jL�-(-�
H.(�����*���r3G�DI(������o��N=
0-�ё�Vf�H��j�]Q`D
+)�1��`��@e�� �z.Qʨt�m��R'�;Si�K���O\��M�䌺�p4��)�Hg�o�24� M�I?��b�$�C�M �I����i���0�uB��������Y�f��/[J#�1'�O�6~"bM{��HU��Q�=��\Hp
o7l��b2�\x�M��J
���7�tl�2�"֚��a����F��8�P�88����+Q�L0�hc�3o�aR��e��^*�t�IJ����1�#/�*�Pҙ
��Z~�S]��lf��n�Ǫ��j�6��xc�˯4�w�
��@,*������nlTK����� )�9J
��(��'�Q�$��o�6fM�? �� ��B��:,���\����,��4�V����>���x�J
��"
��� ��$�����<�b��U��A�Yf�r%NI)����?7�m��n*P��
Y3.�S ��(�]v��Ƕ�:e٢�%�d�
��/,�
��P]�9F�![�ʊ�(I0`�T������`��눌����h�S�s�%
eL�N������� ��l�ݲe�����C����N������{�/_�βX�M�7/���
VJ)�?Ľ�[��Bq\~����E�G���X�B������\�M�m�&�qR�����[[b���&�
��T#w� ���?��Ɯ��A@*��r��+nk"f;�����]~�Iu��T�,�u�44R8��H_�yոyS���8=��R�h4�O��S$U�n����^��=�X����掽��p2!�.���-�|��X�
�D"���u���?���٪��
0��
)� S���J�1
�ɪ׆=�,�
b����]w]ߛ/^���سZ��b�b_t���� �G�!�V����ọ ���Ml���v�}~��
v$���<s��I���k_�z� �,֬[��C?b�T�������6��<���#�%�B�
��[��w�DHI�0'�y�3����d2�5�
S�7��C RQ���ޑ�ᒒ�#g|��[�ޖҿ�Q:��,����n����NPV���ނVJ������e_�d���N��2����q/���3�������T�?F0%��'�kCD�H�-+��+�i�d�`�fD�K}_��RA�o�/����3s��/�O�W���;�;�T<�N�q/:=t��U�"�L`�Vt�b2g�d�)����d��+
�
���P�C�k������7oE��L﵉c�H��8�ED�N��u\�Ez��F� ��A�J���Q#",� �"Z)�+�=w��oTw)P�/�c�
�Q�u�o����D
~�
�S_�S�|�TV
�!�
m���a��X���P�F�v�,�Io)D��{��l���$e�����A�E�jjO�j�NY�9_����o��ƌ9��F郯���c�
��iwHE�K�~��-��KI1�{
3�+**�6�1�
\ӕ@���B����`�
��<
߶m[nٺ��2o���Z
�Ϡ[�J��ӆ]�
(z
����gyC�$g͚��#�<�䓆���F��(++���#�H� �C(�pjkk�.]������y�rJ�;����`dz�F�n�@!�@�17�{L��8
}Փ���:X ?T)��k4�̽�,ZY��;�?�{���^
��� �^�U�>��Kӡ��{���!�v�m;�sNeeeAV6������e�Z[[�?ȡ��v���P8�V���k=��s͎��1mڴU�V����S?FP_��W��_
?���7�\���������D$a̶m�q�� ;������L�:�����[o
r����C����=��c�B&R�ng;�O�d�gB�o~�(
�7����
���S[`=��V��D�c
��e��L(�����g��S�c�@"�q�����E��[�X;k��:|�-\�w��RTZ�����ݚ�����0�u���P8}%9uB���%�r� � $l�9
,�����w����;N�X�|~��3�W8L)�+naT�)��Z��
���?���mJ �#��'T��R_"���`� H�D^dUE���c��ڀ?dp�
:K��}D�S��%;T�kZ��磈Alà�0�G��H�v��$X£J�8$l�-�|�
b
&�Q�9�&s
�/ɐ��3��
��"�f4�[A͆��k������}c*]
��x�"f�hF%B����@fYN<�х�C{H�i3�����`�X>�e�$\����p�F�`�,�
�]]{�zxU�?&�
>j�k���2� y������$�TF�d4�J i�q+ɕ4�5+t��"�
g��`� ��$�(�7҄
��c��.��L���
����7~�1F&��
p�a�7�*d,6�3�Z<�E鍊n2zc;v�č��;�p��7#V���h����
�F�Нӄ`d��w���T��2�У�^���O]�ȕ�
��
��@3z�hhh���8*0mΙ3�� �F��}�h�&{u��w@��Չ�\�i��T���
�SD�,2R�j6D����n�+˶��l���x�&i��W}钉�l�:��}>FX�hQV����p���5��������H�GF��Z�"O�
��k1��(� �+�����W�[8���Ym�r!������ =߱re�D#Dt�ԛ�*9�ɐ
�#Im*c#��{��CŁ�Z5�[�<�.���2:J�4)P�X�;�̐
{�
���h8�t4��L.z��s/p�n��9,(�����B�/|X.P.��0��!�v^[����4����
�
r��Z�S��:�P�a�
+#���ujE�<�w
�.e��9S_�z�Ճ����|���\�[�B����`jI�*)�� �
T�H�16"5ܑ������&�����F�Q�"�$���H�p�tXv�1e�����I�`q�2.�n�"5<�^wZ��-[�����
�h΅Z�~�9u�M�� R� s��z����c�-�؏:��"
�½1^2II��P���A7� �{��7<��SAdO�>|�\�]vY����P�k�t�R)�B����
x`Wy�"�
(a
-w�e�izbw�9~�� �W)���w������A�k
Vy>��ݫ@���!�9�uE��a�P�/74�;H�!X6
3�_���~���y��gaG�����j��C�"�C��r���eeeS�i�Oˏ12j�X�T�v'F�������y~��>�k��)��
�d��^��$
�S)��ڱ3[mD+ojX�p�n�4s�q�e
<Hb�KJ��j}���>�� �+#xX"�8:m"���u`_�9+�G*BJ<�!{�tW:�ܥe�����-GE
�i�
�dB+�9y�
~� ���^3䃋��{=���K����şdP`P`P`P`P`P`P`P`P`P`P`P`P`P`P`�(��#_�������ʜ�h��}��
R��O,>z}�D�n�3-0�>����߁M����V
Ϸ����H�OH���!c���n`�����i�"�fߜ�ju �@A
t��
�ɞ�q$�)" �la��*Ŀwk�>k��3�֭[-Z����'�q�`Nª�����
p�C����LE���s(Sq�TD�QT@�QT@�QT@�QT@�QT@�QT@�QT@�QT@�QT�
P�j���}IEND�B`�
You will need to rename this file to morse.ico first though.
I have not tested the Morse Decoder on a fast laptop so it would be interesting to see if the speed limit is determined by the controllers or the comms / WiFi link, my Morse code protocol or the laptop USB processing and timing.
Other limitations. The labels in the micro:bit are horrible because the code did not fit. After programming, you will need to unplug and reconnect the microbit for Windows to assign it a port. Same thing on power up so the Python programming website will work, however my reset button should work after that provided Python and the required libraries have been installed. It may or may not work if you just use the .exe file (it may need an extra .bat file to reset the port). Changing from very fast to very slow can take a long time to adjust, it is all part of the smoothing and averaging - so use the recalc speed button a few times. If you can send Morse Code by hand at 7 WPM or above it should decode better than most other decoders you will find on the Internet - even the paid ones (in my opinion) !
Did I write all of the code myself ? No it was almost 100% DeepSeek. Did it take ages ? Yes it took months. Was it fun and rewarding ? Absolutely yes, I am really happy with the end result.
