


A webcam watches your hands. Python (using mediapipe) tracks the landmarks of both hands in real-time, translates them into angles for the 4 servomotors of the arm, and sends them via serial port to an Arduino which applies them.
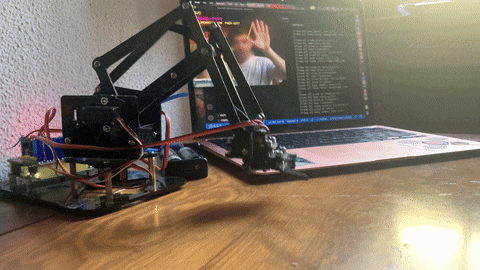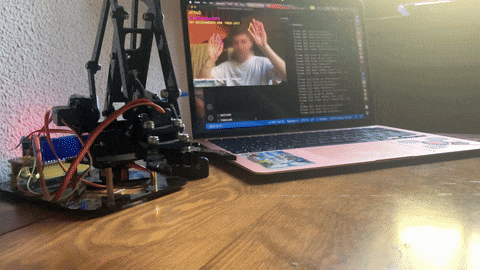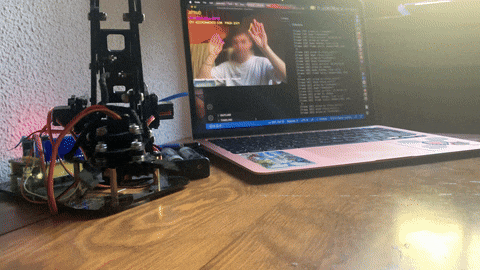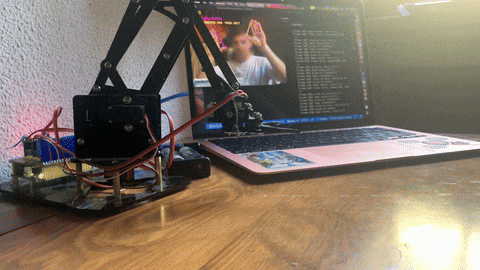
Devices & Components
1
Arduino Uno Rev3
1
Keyestudio 4DOF Robot Arm Kit
Instructions
Control.py
Left hand: Thumb-index pinch → BASE rotation (pin A1)
Right hand: Hand height in the frame → arm extension: moves SHOULDER (pin A0) and ELBOW (pin 6) together in a coordinated way (hand high = arm extended forward, hand low = arm retracted) Thumb-index pinch → GRIPPER control (pin 9)
Safety
If a hand leaves the frame, its axis remains locked at the last commanded value (no sudden jumps) Spacebar → full pause of all servo motors
'q' → exit
CODE